● EMBODIED INTELLIGENCE · Embodied AI
Give intelligence
a body.
Edge foundation models for robots, integrating perception, planning and control.
High-precision force control for assembly, grasping and human-robot collaboration.
Fusion of vision, touch and force for unstructured environments.
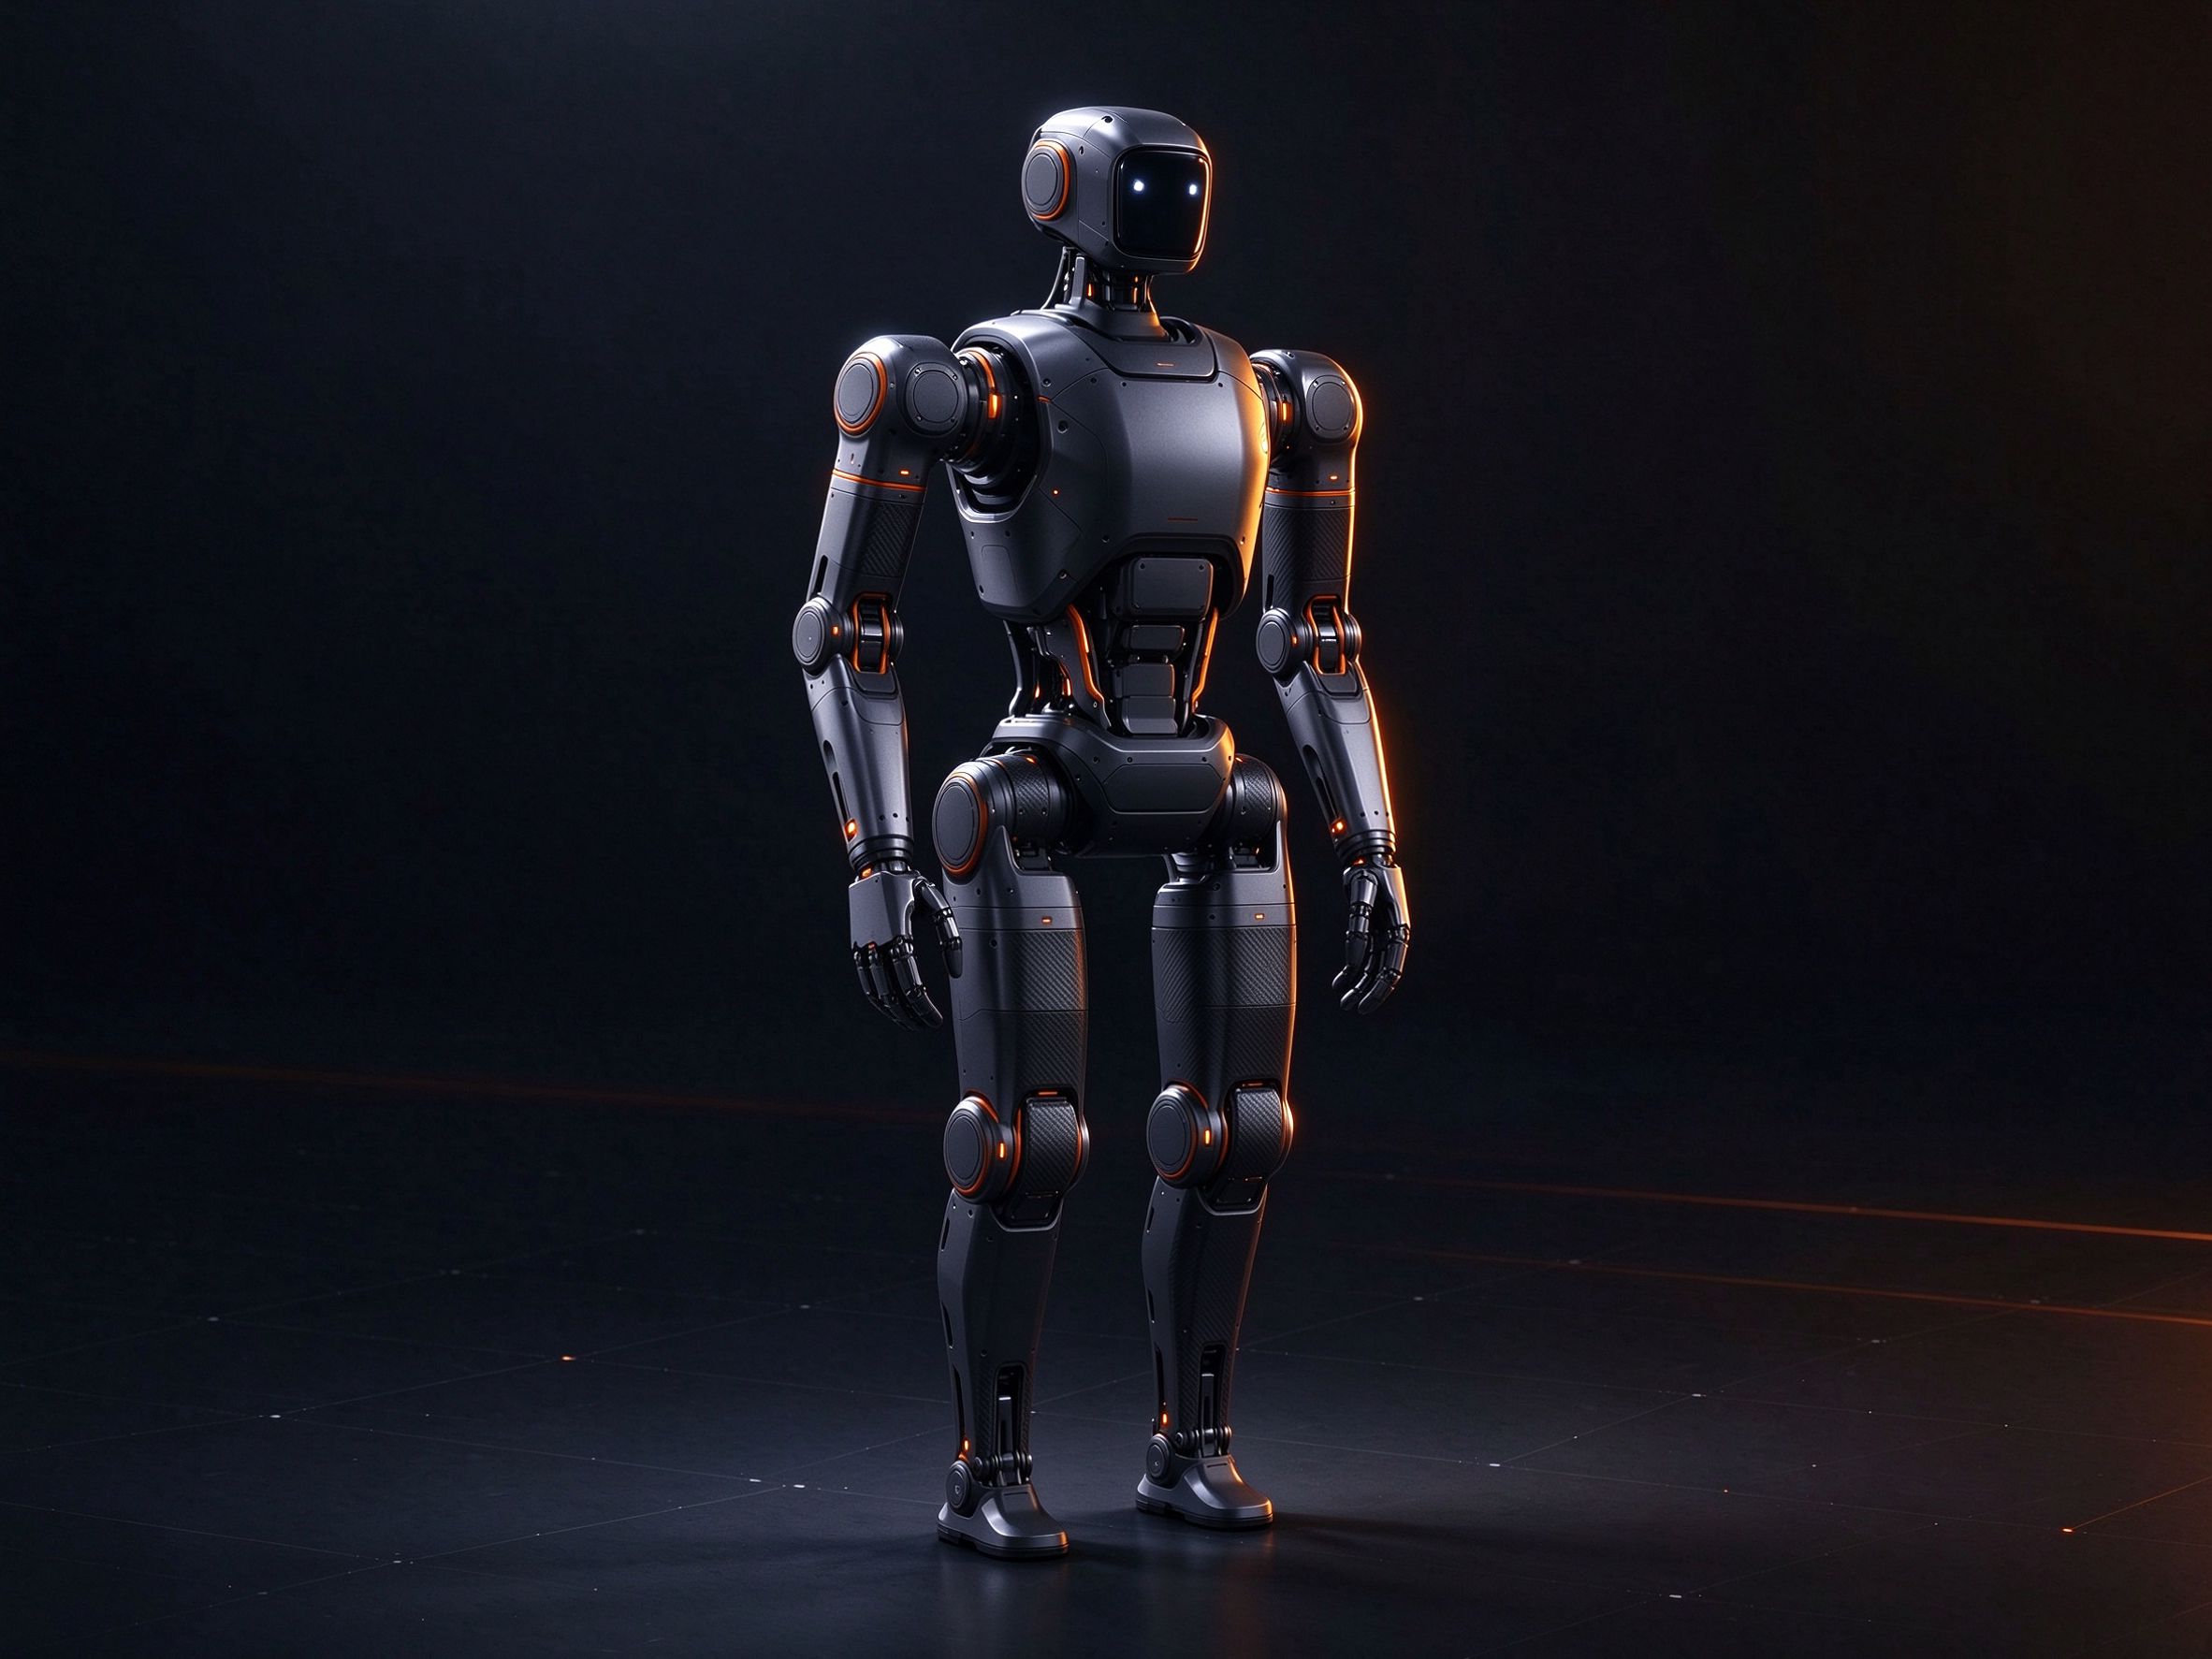
Versatile humanoid platform for research, industrial validation and commercial deployment.
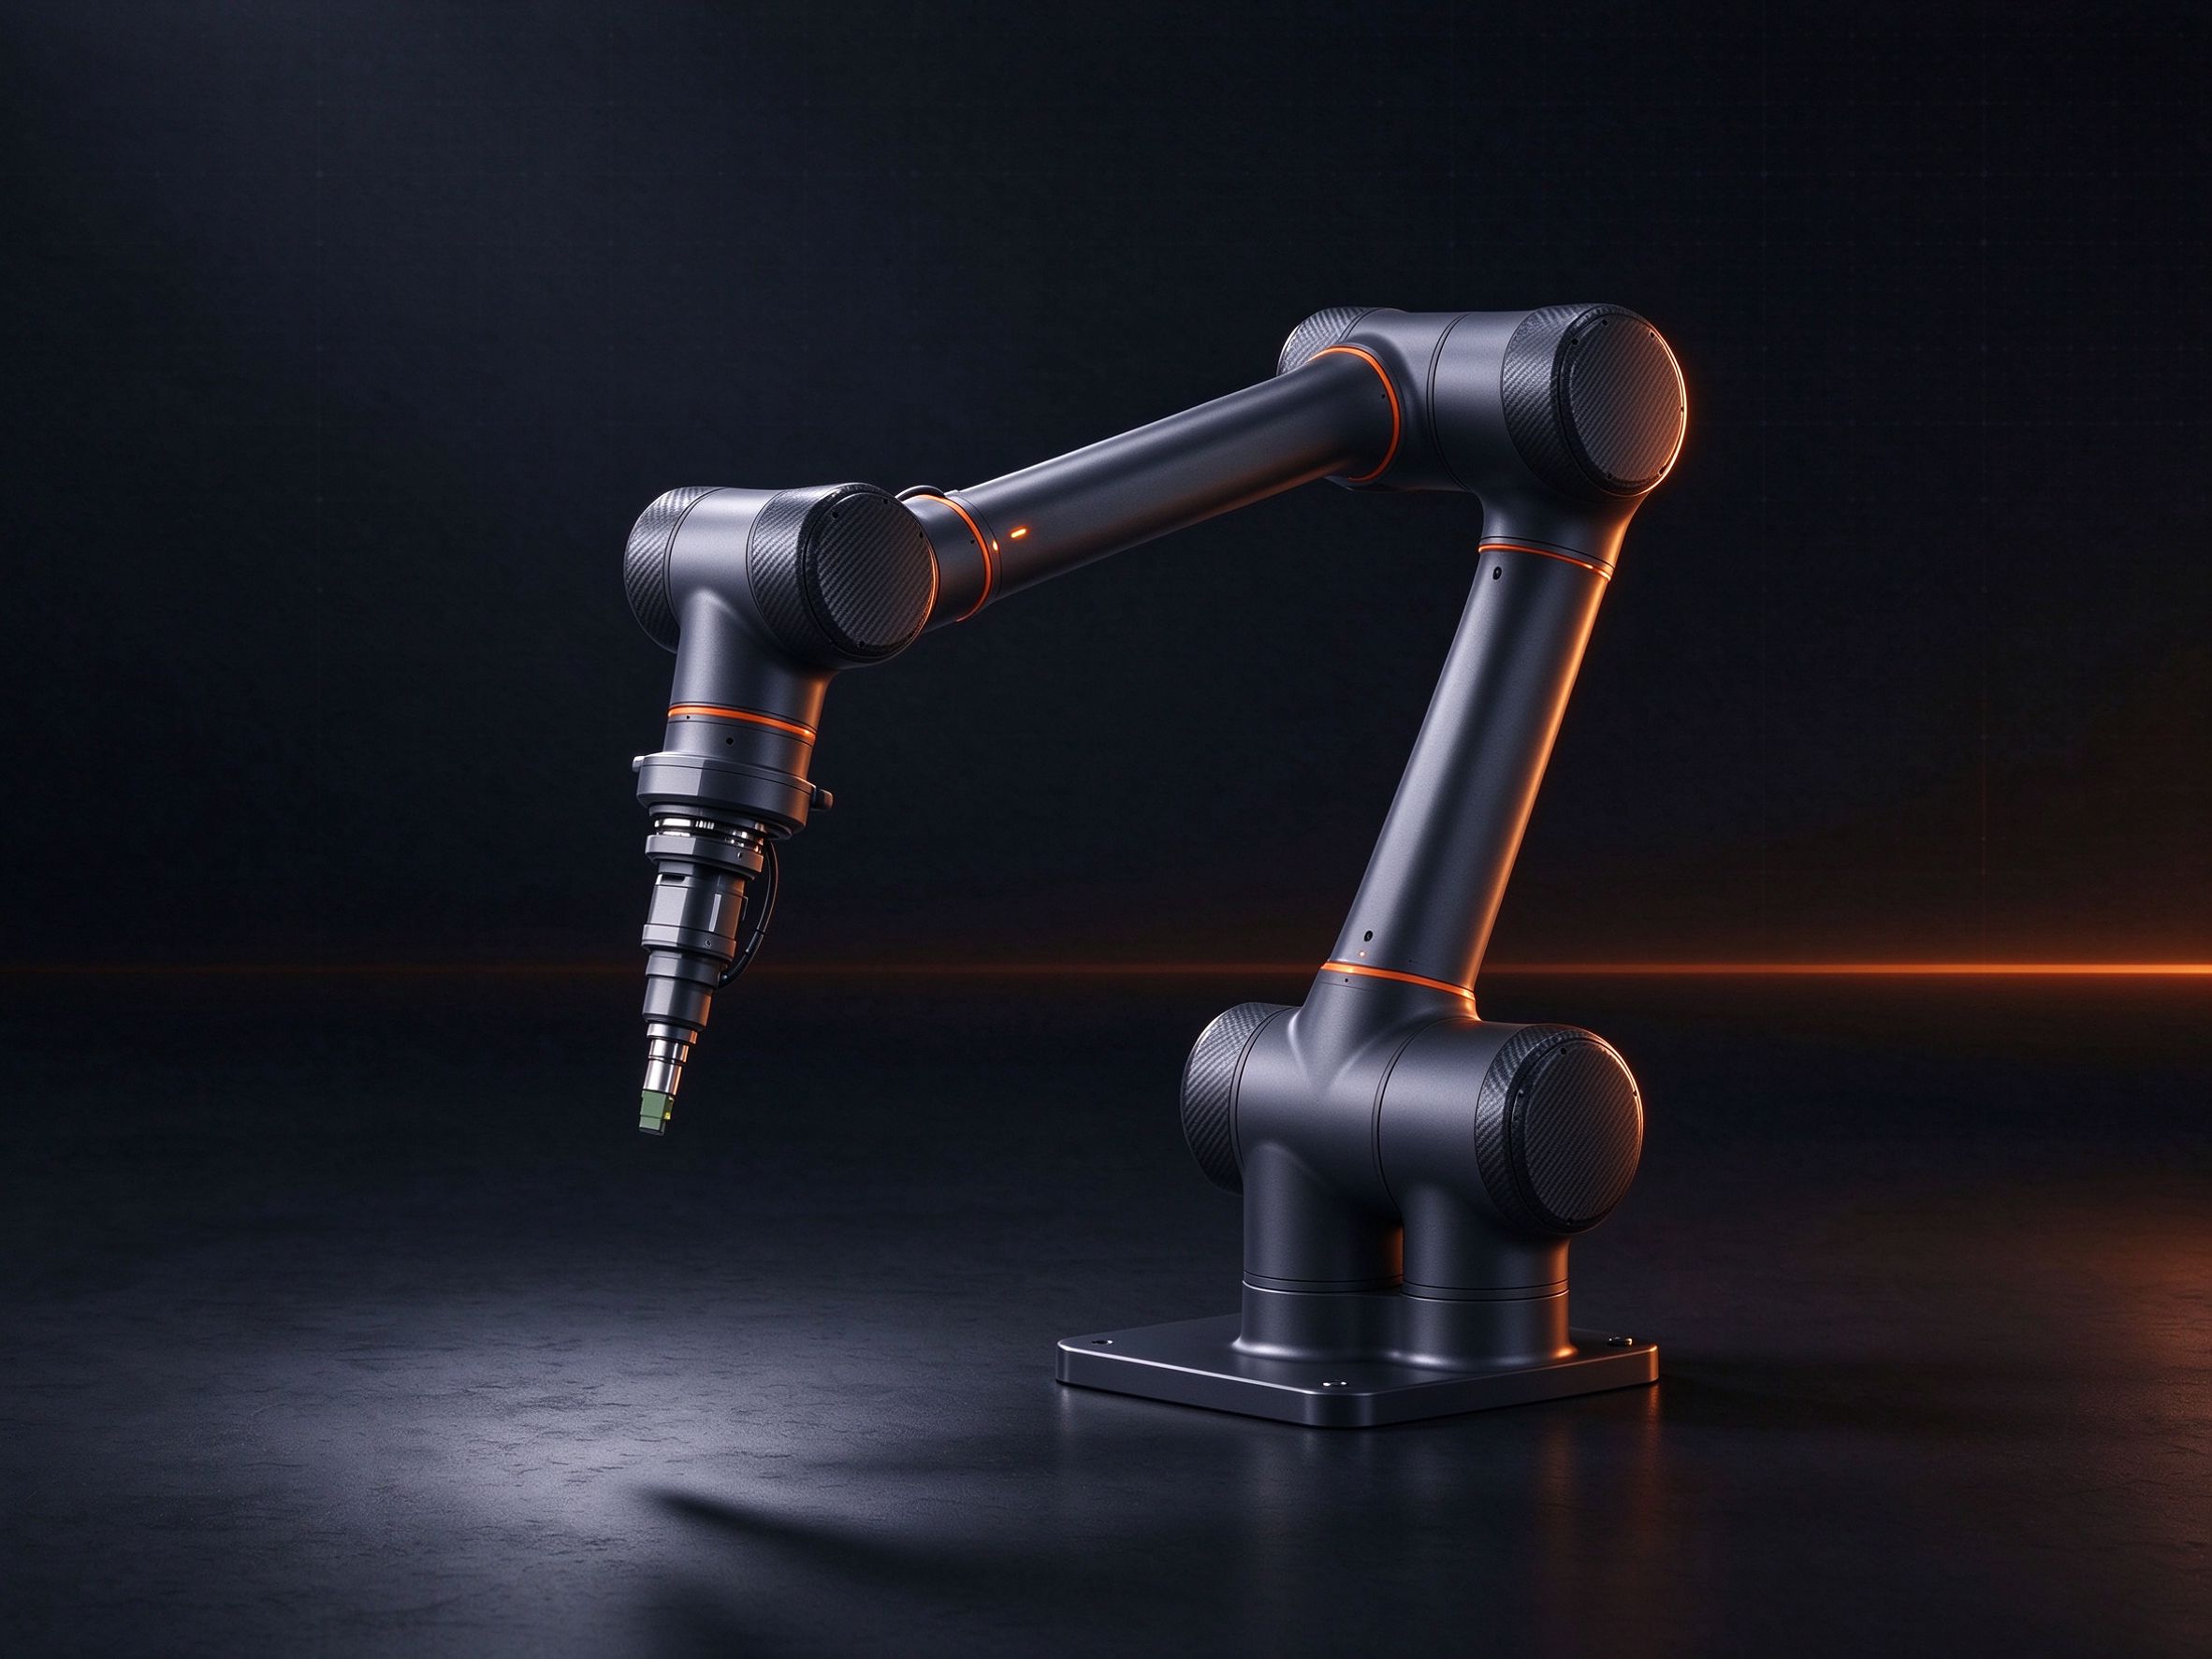
Highly flexible force-controlled arms for precision assembly and human-robot coexistence.
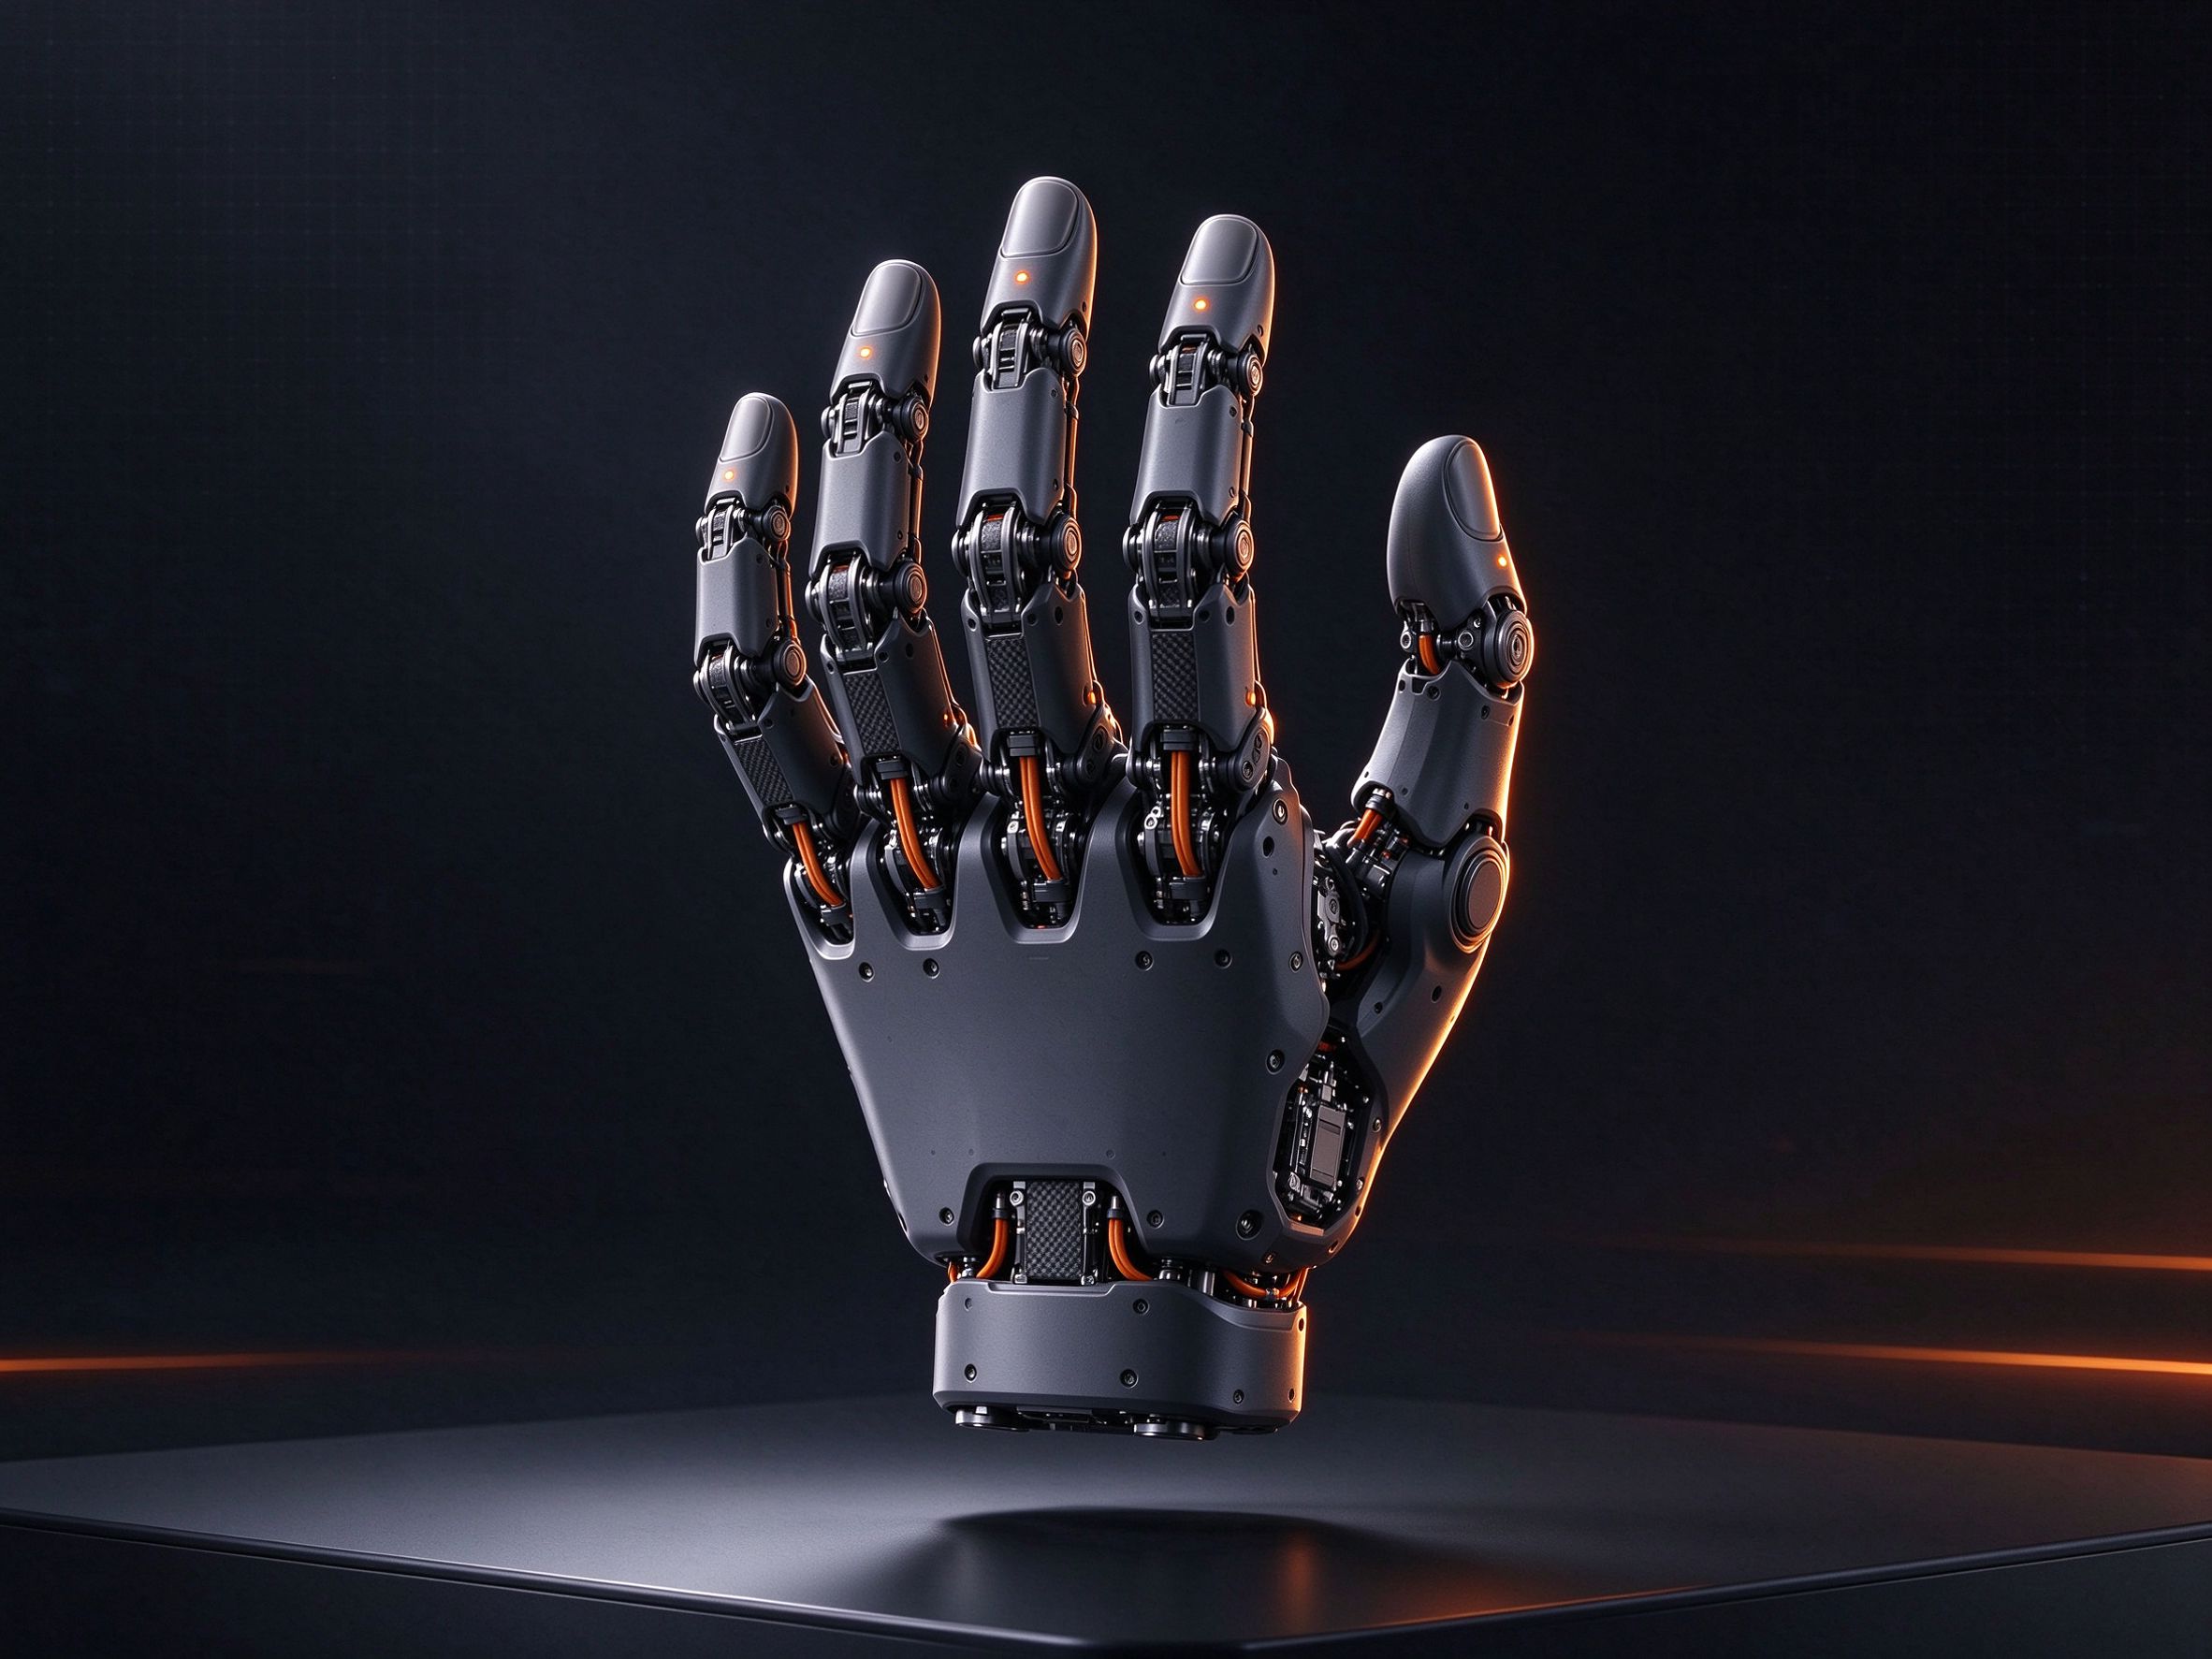
Multi-DOF dexterous grasping for complex object manipulation.
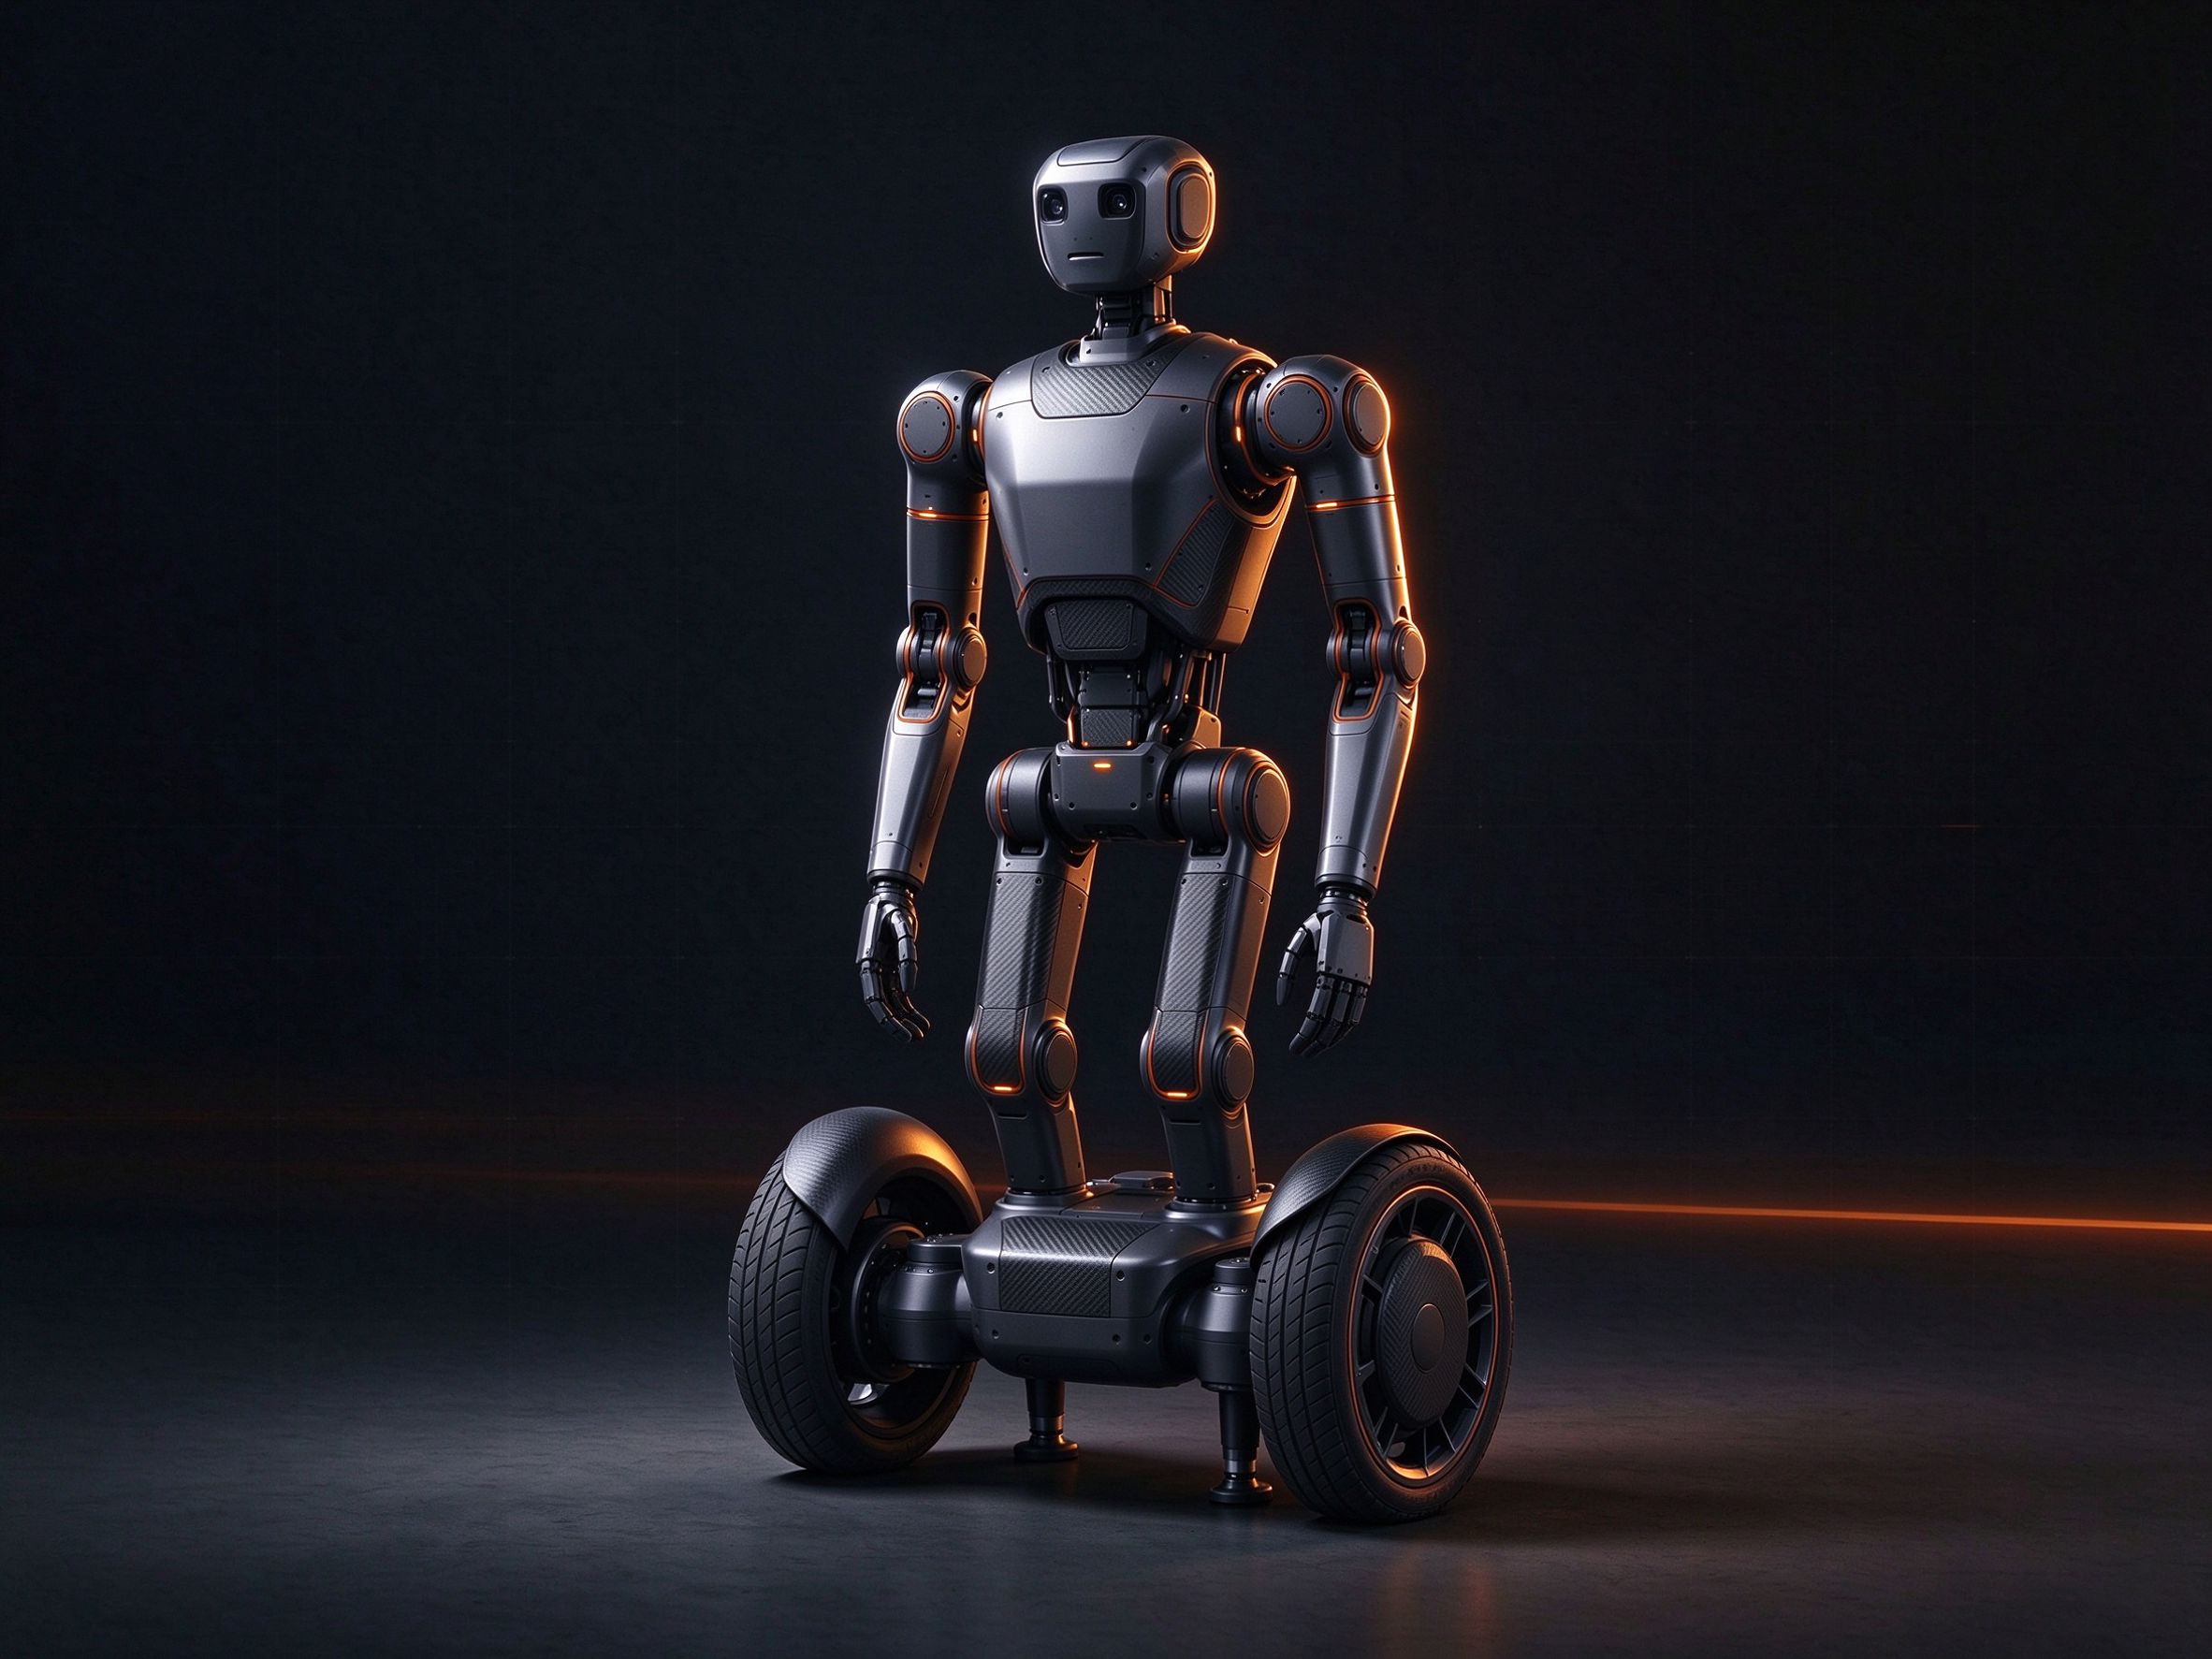
Wheeled base with humanoid torso for inspection, transport and mobile manipulation.
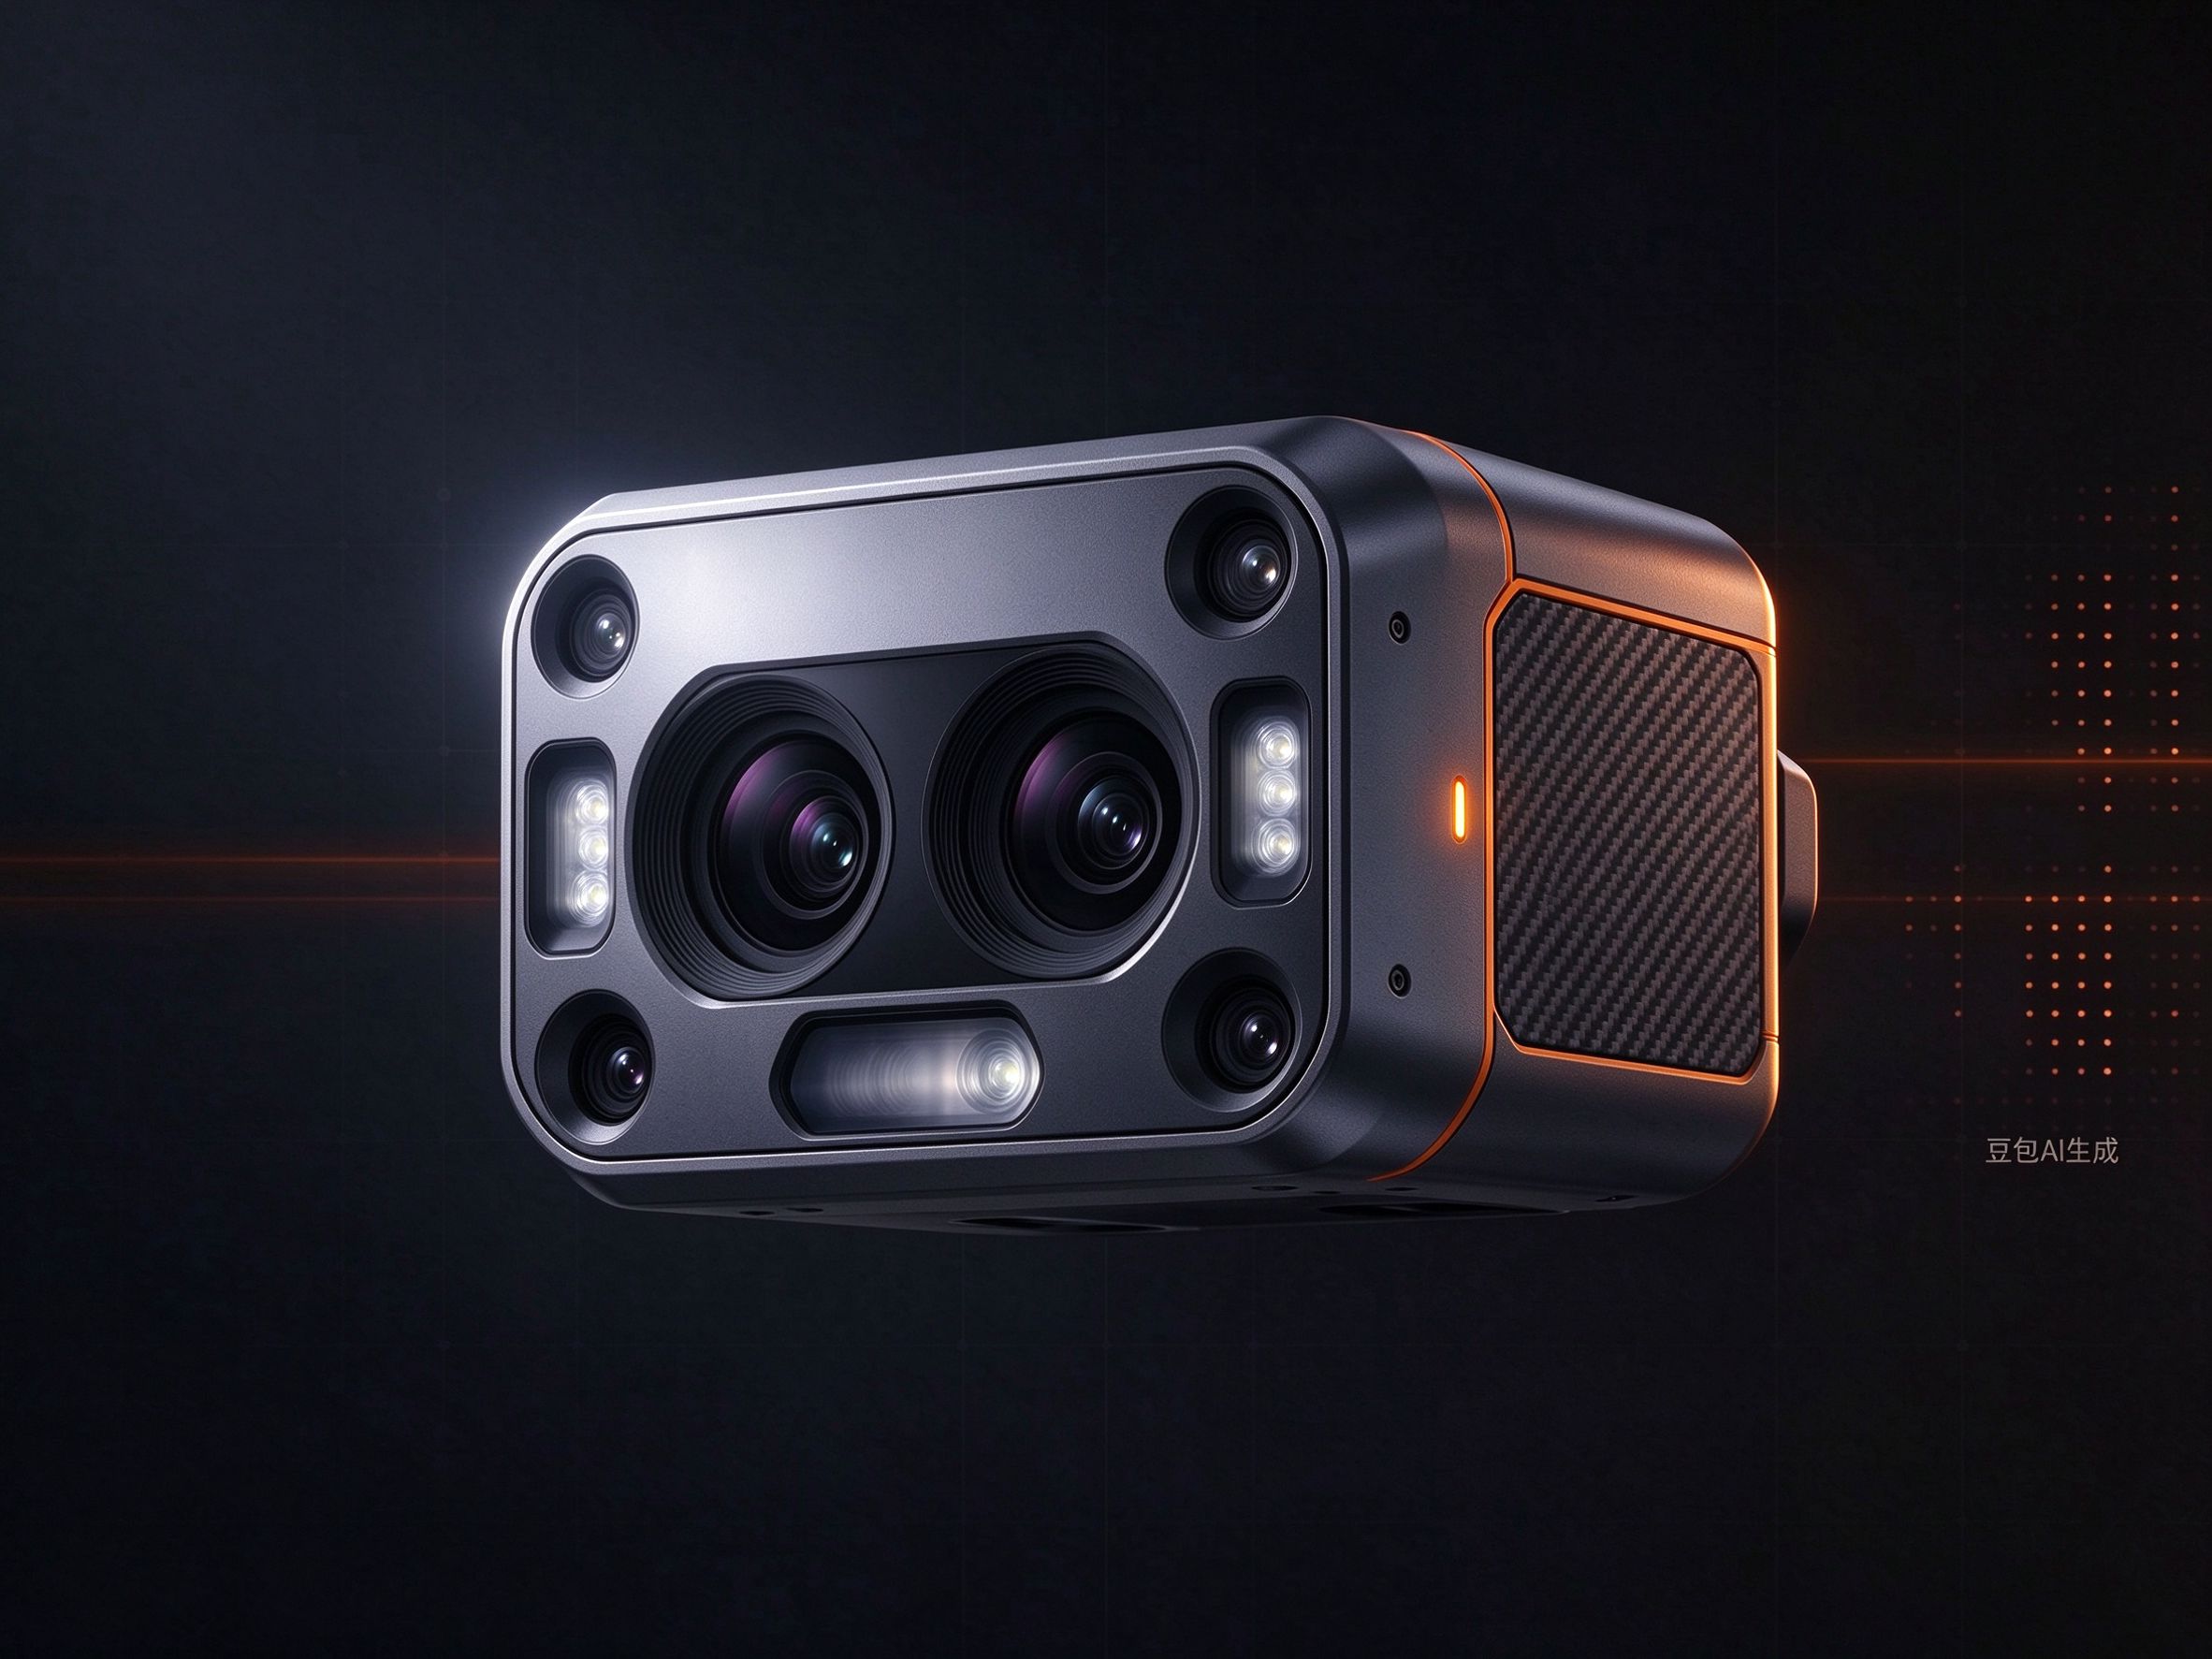
Intelligent 3D vision modules for robots, providing depth perception and scene understanding for navigation, obstacle avoidance and precision manipulation.
Flexible line assembly, parts sorting and precision inspection.
Dynamic pick-and-place, palletizing and handling of variable objects.
Embodied AI research platforms for universities and labs.
We focus on embodied intelligence and robotics, bringing AI models into the physical world to create commercially deployable robotic hardware and software solutions.
Registered in Hong Kong on 23 January 2025.